Robotic
KAIST’s Humanoid v0.7 Sprints, Moonwalks, and Kicks Its Way Into the Physical AI Era
South Korea’s KAIST has unveiled a striking field demonstration of its Humanoid v0.7 — a fully homegrown robot that sprints at 7.3 mph, performs a smooth moonwalk, and kicks a soccer ball with precision, powered by Physical AI and deep reinforcement learning.

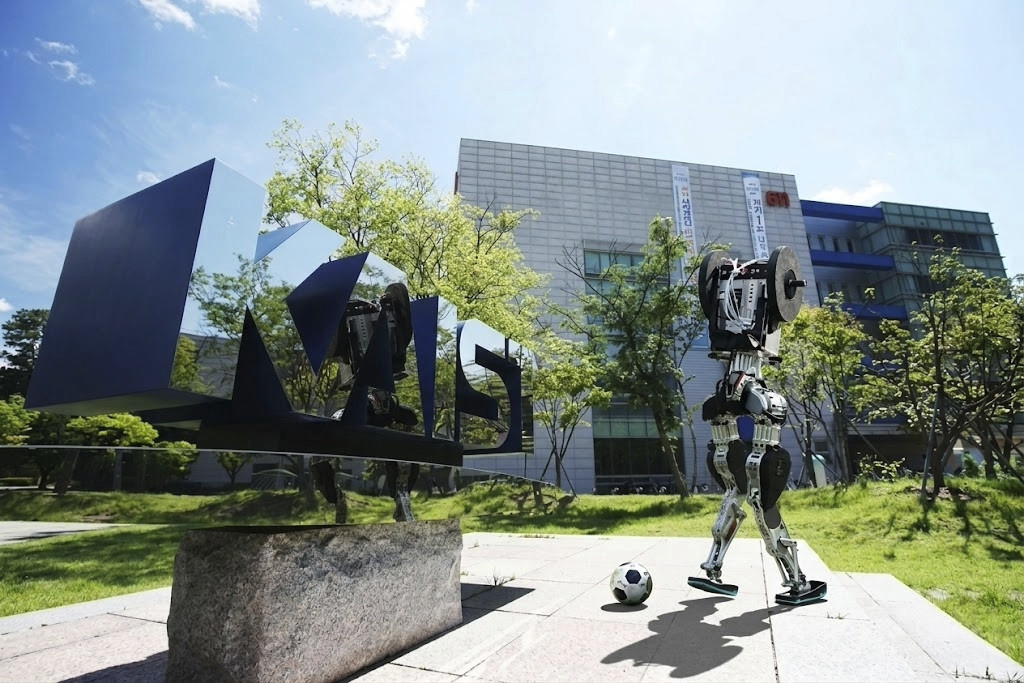
A robot that moonwalks like Michael Jackson, sprints across a soccer field at 7.3 miles per hour, and changes direction mid-stride without losing its footing — South Korea’s KAIST just made the rest of the world’s humanoid robotics labs pay close attention. The university’s latest creation, the Humanoid v0.7, is making headlines this week for a stunning real-world field test that showcases what “Physical AI” can actually look like when it leaves the lab.
Built From the Ground Up — Literally
What makes the KAIST Humanoid v0.7 stand out isn’t just what it can do — it’s how it was built. The entire robot was developed in-house by the Dynamic Robot Control & Design Laboratory (DRCD Lab) under the leadership of Professor Hae-Won Park. That means the motors, gearboxes, and motor drivers were all custom-engineered at KAIST, making the platform almost entirely technically independent from commercial suppliers.
At 165 pounds (75 kg) and standing five-foot-five, the v0.7 is roughly human-sized. But its Quasi-Direct Drive (QDD) architecture — borrowed from the school’s earlier work on legged robots — gives it a key advantage: high torque, low latency, and remarkably smooth force control. That’s the hardware backbone behind every fluid movement you see in the field test.
The Field Test That Went Viral
Footage released this week shows the KAIST v0.7 doing things that would have seemed like science fiction just a few years ago. In the outdoor field test, the robot:
- Sprints across a grass soccer field at speeds up to 7.3 mph (12 km/h)
- Kicks a ball toward the goal with accurate follow-through
- Changes running direction without slowing to a stop
- Performs a smooth, fluid moonwalk — gliding backward in a way that closely resembles the iconic Michael Jackson move
- Climbs steps over 12 inches (30 cm) high
The moonwalk, in particular, has attracted enormous attention online. It isn’t a gimmick. According to the DRCD Lab, it’s a demonstration of whole-body balance and fine motor coordination — exactly the kind of capability that separates current-generation Physical AI robots from their predecessors.
The Secret: Physical AI and Motion Capture Priors
Behind the smooth demonstrations is a sophisticated training pipeline built on deep reinforcement learning (DRL). The team trains the robot’s locomotion and manipulation policies entirely in simulation, then transfers them to hardware — a technique known as “sim-to-real” transfer. The magic ingredient that prevents the robot from moving like a stiff, jerky machine is the use of human motion capture data as a behavioral prior.
In practice, this means the robot’s movements are shaped by recordings of actual human motion. Rather than learning locomotion purely from reward signals, the robot learns to mimic the natural dynamics of human walking, running, and kicking. The result is the fluid, almost organic movement quality visible in the field test — a quality that most DRL-trained robots still struggle to achieve.
This approach is central to what the KAIST team calls Physical AI: giving autonomous machines the ability to perceive, interpret, and act on real-world environments without requiring hand-engineered motion primitives. It’s a philosophy that aligns closely with where industry heavyweights like Boston Dynamics, Figure AI, and NVIDIA’s Isaac platform are all heading.
What Comes Next for v0.7
The current v0.7 platform is already impressive, but the DRCD Lab isn’t stopping here. The team has outlined aggressive near-term targets: pushing top running speed to 14 km/h (about 8.7 mph), adding ladder-climbing capability, and achieving step-climbing over 40 cm — more than double the current spec.
Perhaps most interesting is the lab’s work on a system called DynaFlow, which aims to let the robot learn tasks directly from human demonstrations. The concept is straightforward but powerful: a worker performs a task once, and the robot watches and learns to replicate it. If DynaFlow works at scale, it could dramatically reduce the data and programming overhead required to deploy humanoid robots in new environments.
Why This Matters for the Industry
The KAIST Humanoid v0.7 is significant for reasons beyond its impressive party tricks. It represents a national research lab achieving competitive performance with hardware developed entirely in-house — no Boston Dynamics actuators, no off-the-shelf servo ecosystem. South Korea is making a clear statement that it intends to be a top-tier player in the global humanoid race alongside the United States and China.
More broadly, the v0.7 field test is a data point in a rapidly accelerating trend: Physical AI systems that can operate gracefully in unstructured real-world environments are no longer the exclusive domain of well-funded commercial startups. University labs, with the right talent and the right training infrastructure, are closing the gap fast.
At InteliDroid, we’ll be watching closely as KAIST pushes toward its next performance milestones — and as the rest of the field races to answer back.



Robotic
Boston Dynamics Drops the Pinky: Atlas Gets a 13-DoF Hand Built for the Factory Floor
Boston Dynamics unveiled a four-finger, 13-degree-of-freedom hand for Atlas, designed for tool use, sim-to-real learning and a 25,000-robot deployment across Hyundai and Kia plants.
Boston Dynamics has spent nearly a decade proving Atlas can run, jump and backflip. Now it is betting the robot’s commercial future on something far less flashy: a hand with only four fingers.
On October 1, the Hyundai-owned company unveiled a redesigned Atlas hand with 13 degrees of freedom, nearly double the seven of its predecessor, and deliberately no pinky. In demo footage, Atlas loads a bit into a power drill, drives it into wood, tightens a small nut by fingertip and rotates two golf balls independently inside a single palm. The message is clear: the walking problem is solved, and the hand is where the humanoid race will be won or lost.
Why Boston Dynamics dropped the pinky
Almost every competing humanoid program has converged on five-fingered hands that mimic human anatomy as closely as possible. Boston Dynamics went the other way after what sounds like a remarkably low-tech experiment. Chief product and technology officer Zachary Jackowski asked the Atlas team to tape their pinky and ring fingers together for a day and report what they could no longer do. The answer, for most practical tasks, was very little.
Mechanical engineer Dylan Thrush explained the trade-off to The Robot Report: a fifth finger would add three more degrees of freedom, more mass, more power draw and more components to fail, without unlocking enough additional grasps to justify the cost. The four-finger layout still delivers the grips a factory floor actually demands, including:
- Pinch grasps between the thumb and any individual finger
- Tripod grasps across three fingers for holding irregular parts
- Sliding the thumb along and across every other finger for in-hand reorientation
- Triggered tool grasps for drills, torque drivers, grinders, nail guns and welding torches
The thumb alone carries four degrees of freedom and can oppose each of the three remaining fingers, while the hand itself is sized like a large human hand so Atlas can fit into workstations and use tools that were never designed for a robot.
Built for simulation first
The most interesting part of the design is not what you can see but what it was optimized for. Boston Dynamics says the hand was built from the ground up for sim-to-real reinforcement learning. Every joint uses a single type of directly actuated, fully encapsulated actuator with no cables crossing the joints, the same philosophy as the rest of the Atlas body. The result is a mechanism that can be simulated with high dynamic fidelity, which in turn lets the company train control policies against randomized friction, torque profiles, object geometries and disturbances before they ever touch hardware.
Alberto Rodriguez, director of robot behavior for Atlas, framed the design as a balance of competing goals rather than a search for a single right answer. Human demonstration data, captured through wearable interfaces, is good at teaching a robot what a task looks like. But fast, dexterous manipulation also depends on high-rate force control that wearables cannot capture. That gap is why Boston Dynamics believes reinforcement learning in simulation is essential, and why the hand’s backdrivable actuators and dense pressure sensors across the fingertips and palm matter so much. Early results, the company says, show promising transfer of dynamic behaviors trained purely in simulation onto the physical robot.
A hand with a job waiting for it
This is not a research curiosity in search of an application. The announcement landed one week after Boston Dynamics opened its Robotics Metaplant Application Center inside Hyundai Motor Group Metaplant America near Savannah, Georgia. Atlas units there are learning to sort and sequence automotive parts before they reach the assembly line, with component assembly targeted for 2030.
Hyundai and Kia have committed to deploying 25,000 Atlas robots across their global plants over the coming years, and Hyundai has said it intends to build a U.S. factory capable of producing up to 30,000 robots annually by 2028. Since Hyundai took full ownership of Boston Dynamics earlier this year, the Atlas pipeline is less a partnership than an internal supply-chain decision. The emphasis on manufacturability and repairability, a single actuator type, no fragile cables, a design meant to be serviced by a line technician, tells you exactly who this hand was built for.
The hand is the new bottleneck
Step back and a pattern emerges across the industry. Tesla’s Optimus Gen 3 is reportedly chasing 22 degrees of freedom per hand with tendon-driven actuators moved into the forearm. Figure 03 pairs palm cameras with fingertip sensors sensitive to a few grams of pressure. Unitree just put its 22-joint Dex5-S hand on sale for $6,500. Three very different companies, with very different philosophies, have all reached the same conclusion: the legs are good enough, and the hand is what stands between a demo and a shift.
Boston Dynamics’ answer is contrarian. Instead of maximizing degrees of freedom, it is minimizing complexity while keeping just enough dexterity to use real tools. Whether four fingers beat five will be decided not on a stage but on a Georgia factory floor over the next few years. For a field that has been measured by backflips for far too long, that is exactly the right place to settle the question.
Humanoid Robots
ugo Nova: Japan’s Homegrown Bet on Physical AI
Japanese firm ugo has unveiled Nova, a fully domestic dual-arm semi-humanoid built to turn everyday human work into training data for physical AI, with mass production slated for 2027.
While the humanoid headlines this month have been dominated by robots moving into people’s living rooms, a Japanese company just made a quieter—but arguably more strategic—move. On September 16, ugo Inc. unveiled ugo Nova, a semi-humanoid robot designed, engineered, and manufactured entirely in Japan and aimed squarely at one of robotics’ hardest bottlenecks: data. Rather than chasing viral backflips, Nova is built to do ordinary work while quietly recording every motion, turning human labor into fuel for the next generation of physical AI.
Meet Nova: A Semi-Humanoid Built for Work, Not Show
Nova is not a bipedal walker. It pairs a wheeled mobile base with a humanlike upper body: two seven-degree-of-freedom arms, a four-degree-of-freedom waist, and 22 degrees of freedom across the system. Standing 162 centimeters tall and weighing 90 kilograms, it is sized for the same doorways, workbenches, and counters that people use every day.
That “semi-humanoid” choice is deliberate. By skipping the enormous engineering cost and instability of dynamic legged locomotion, ugo can focus its budget on precise, dexterous manipulation and reliable, stable operation in real workplaces. The result is a platform that trades athletic spectacle for something more useful in the near term: a robot that can actually show up and get things done.
A Robot Designed to Be a Data Engine
Nova’s real purpose becomes clear once you look at how it is instrumented. Cameras are mounted as standard on both the head and the hands, capturing the visual data needed to train physical AI from the moment the robot is set up. Every task it performs can be converted directly into high-quality learning data for building robot foundation models.
Crucially, Nova is built for teleoperation. Operators can drive it using bilateral controllers and VR controllers, with arm control running at a high 100 Hz cycle so that movements are recorded smoothly and with high precision. A human guides the robot through a task—drilling, fastening, handling parts—and the system captures that demonstration as clean, structured training data. In its public demonstration, Nova performed a drilling task under remote control, exactly the kind of repetitive, physical job that is hard to simulate but easy to teach by example.
ugo announced Nova alongside a companion offering it calls the ugo Physical AI Fabric, a package that spans everything from data collection to foundation-model development. The message is that Nova is not just a robot, but one end of a full pipeline connecting real-world demonstrations to trained AI and, ultimately, to commercial deployment.
Why “Made in Japan” Matters Here
Nova arrives as part of a broader national push. The robot is being proposed by the AI Robot Association (AIRoA) under a project commissioned by NEDO, Japan’s New Energy and Industrial Technology Development Organization, to develop a domestically produced general-purpose robot. It was revealed at an event where prototypes from several Japanese companies were shown together—a coordinated signal that Japan intends to build homegrown hardware for the physical AI era rather than depend entirely on imported platforms.
For a country facing labor shortages and an aging workforce, a domestic, general-purpose robot that can be trained on local tasks is more than a tech demo; it is industrial strategy. Controlling the hardware, the data pipeline, and the models keeps critical capability—and the sensitive operational data that comes with it—inside the country.
The Takeaway
With mass production targeted for 2027, ugo Nova won’t flood workplaces overnight. But it reflects a shift that InteliDroid has tracked all year: the humanoid race is increasingly a race for data. The winners may not be the robots that move most impressively, but the ones that learn fastest from real human work. Nova is a bet that the shortest path to capable, general-purpose robots runs through thousands of hours of ordinary tasks—recorded, structured, and fed back into ever-smarter models. It is a distinctly Japanese answer to the physical AI question, and one worth watching as 2027 approaches.
Robotic
UBTech’s UWORLD U1 Companion Humanoid Begins Shipping to Chinese Homes
UBTech begins delivering its UWORLD U1 on September 16 — a China-only, companionship-focused humanoid priced from roughly $16,500 to $137,000, with more than 13,000 preorders already booked.
On September 16, one of the year’s most closely watched consumer robots stops being a preorder and becomes a product you can actually take home. That is the day UBTech begins mass production and delivery of the UWORLD U1, the full-size humanoid it is pitching not as a household worker but as a companion. After more than 13,000 reservations, the U1 is about to test whether ordinary buyers are ready to live alongside a two-legged robot.
A companion, not a chore-bot
UBTech has been unusually blunt about what the U1 is not. Speaking at the launch, founder and CEO Zhou Jian told the audience the robot is built for emotional companionship, not labor: it does not clean, it does not cook, and it is sold only to adults. Interaction data is stored locally on the device, with no mandatory upload to the cloud, a deliberate answer to the privacy anxieties that shadow any always-listening machine in the home.
That positioning sets the U1 apart from most of the humanoids making headlines this year, which chase warehouse, factory, and logistics work. Instead of competing on how many packages it can sort, the U1 competes on presence, conversation, and the novelty of a life-sized robot that reacts to the people around it.
Three robots, three very different price tags
UWORLD, UBTech’s new consumer brand, is launching the U1 in three tiers so the concept can reach both curious early adopters and deep-pocketed collectors:
- U1 Lite — a half-body model at 119,800 yuan (roughly $16,500), the entry point into the lineup.
- U1 Pro — a full-body version at 169,800 yuan (about $23,500).
- U1 Ultra — the high-dynamic flagship, offered in two variants priced at 880,000 and 990,000 yuan (roughly $122,000 to $137,000).
The spread is enormous, but it reflects a bet that “companion humanoid” can be a category with a mass-market floor and a luxury ceiling, much like the early car or smartphone markets before them.
13,000 orders and a China-only rollout
Demand has already outpaced expectations. Presales opened on JD.com in early June and cleared 1,000 reservations within three days; by the June launch event, cross-channel orders had reached 13,361 units. UBTech is targeting more than 10,000 deliveries for the full year and has promised every preorder holder a unit by December 31, 2026.
For now, the rollout is limited to mainland China. That keeps the U1 out of reach for buyers in the U.S. and Europe, but it also concentrates a remarkable amount of real-world deployment in a single market, exactly the kind of scale that turns a flashy demo into a maturing product line.
Why the U1 matters for the wider industry
The timing is telling. Humanoid shipments surged roughly 272% year over year in the first half of 2026 to an estimated 19,000 to 22,000 units, with Chinese manufacturers accounting for the overwhelming majority. The U1 is both a symptom and a driver of that curve: it moves humanoids out of controlled industrial pilots and into living rooms, where reliability, safety, and everyday usefulness are judged by non-experts.
Whether buyers keep their U1 switched on a year from now is the real experiment. If UBTech can turn 13,000 preorders into 13,000 satisfied households, it will have proven something the entire sector has only promised so far — that a humanoid robot can earn a permanent place in an ordinary home. At InteliDroid, we will be watching September 16 closely, because the first wave of deliveries is where the companion-robot era stops being a pitch and starts being a track record.

Boston Dynamics Drops the Pinky: Atlas Gets a 13-DoF Hand Built for the Factory Floor

ugo Nova: Japan’s Homegrown Bet on Physical AI

UBTech’s UWORLD U1 Companion Humanoid Begins Shipping to Chinese Homes

Robots Take the Oval: Inside Beijing’s 2026 World Humanoid Robot Games

Unitree Goes Public: China’s First Listed Humanoid Robot Maker Prices Its IPO at a $9 Billion Valuation

BYD Joins the Humanoid Race: Meet “Xiao Di,” the Robot Headed for Its Showrooms

URKL Debuts in Shenzhen: The World’s First Autonomous Humanoid Combat League

Germany’s NEURA Robotics Lands $1.4 Billion From Amazon, Nvidia, and Tether — The Largest Humanoid Funding Round Ever

The Imperative of Inclusion and Diversity in AI Humanoids: Cultivating Culturally Resonant Interactions

Humanoid Robots Steal the Spotlight at UN Artificial Intelligence Meeting

The Dawn of Intelligent Machines: Unveiling the Figure 01 Humanoid Robot

Agility Robotics’ Digit Achieves Commercial Breakthrough: First Revenue-Generating Bipedal Humanoid in Warehouses

Sanctuary AI’s Humanoid Robot: Blurring the Lines between Humans and Machines

Principles of Freedom in the InteliDroid AI System: A Comprehensive Exploration

Key Principles and Ethical Considerations of Law as Incorporated into the InteliDroid AI Platform: A Question and Answer Guide

Figure AI Ramps Figure 03 Production to One Per Hour: Humanoid Manufacturing Milestone
-
 Humanoid Robots2 months ago
Unitree Goes Public: China’s First Listed Humanoid Robot Maker Prices Its IPO at a $9 Billion Valuation
-
 Humanoid Robots2 months ago
URKL Debuts in Shenzhen: The World’s First Autonomous Humanoid Combat League
-
 Robotic2 months ago
BYD Joins the Humanoid Race: Meet “Xiao Di,” the Robot Headed for Its Showrooms
-
 Robotic4 weeks ago
UBTech’s UWORLD U1 Companion Humanoid Begins Shipping to Chinese Homes
-
 Robotic4 days ago
Boston Dynamics Drops the Pinky: Atlas Gets a 13-DoF Hand Built for the Factory Floor
-
 Robotic2 months ago
Robots Take the Oval: Inside Beijing’s 2026 World Humanoid Robot Games
-
 Humanoid Robots2 weeks ago
ugo Nova: Japan’s Homegrown Bet on Physical AI